Get Started with Point Cloud Toolbox
R2026bPoint Cloud Toolbox™ provides algorithms and apps for designing and analyzing point cloud processing systems. The toolbox provides functions for registration, filtering, geometric transformation, clustering, and segmentation of point clouds. It supports processing point cloud data from sensors such as lidar, RGB-D cameras, stereo cameras, and mmWave radar, and from workflows such as visual SLAM, photogrammetry, and structure-from-motion.
You can read data from standard formats or stream it directly from lidar sensors. Visualization tools support analysis, measurement, and interactive editing of large point clouds.
Apps enable lidar-camera calibration, multi-sensor labeling, and registration. You can apply deep learning techniques for the detection, segmentation, and classification of point clouds. You can also generate C/C++ (with MATLAB® Coder™) and CUDA® codes (with GPU Coder™) for deployment.
Tutorials
- Read, Process, and Write Lidar Point Cloud Data
This example shows how to read a point cloud into the workspace, select a desired set of points, and then write the selected points to a point cloud file format.
- Extract Ground Points and Non-Ground Points from Lidar Data
Read lidar data from a PCAP file by using the
velodyneFileReaderfunction. - Match and Visualize Corresponding Features in Point Clouds
This example shows how to match corresponding features between point clouds using the
pcmatchfeaturesfunction and visualize them using thepcshowMatchedFeaturesfunction. - Estimate Transformation Between Two Point Clouds Using Features
This example shows how to estimate a rigid transformation between two point clouds.
About Point Cloud Processing
- Introduction to Lidar
High-level overview of lidar concepts and applications.
- What Is Lidar-Camera Calibration?
Fuse lidar and camera data.
- Implement Point Cloud SLAM in MATLAB
Understand point cloud registration and mapping workflow.
- Deep Learning with Point Clouds
Learn point cloud processing using deep learning.
Featured Examples
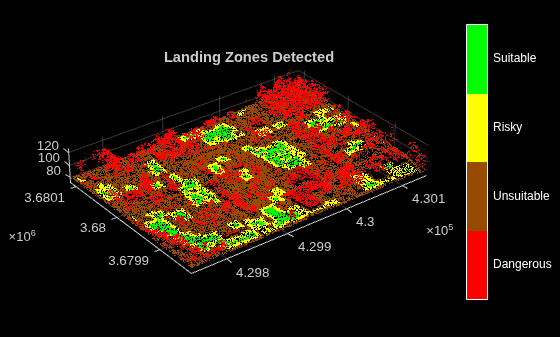
Determine Safe Landing Area for Aerial Vehicles
Demonstrates how to determine a safe landing area for aerial vehicles, such as helicopters and UAVs, by using aerial lidar data.
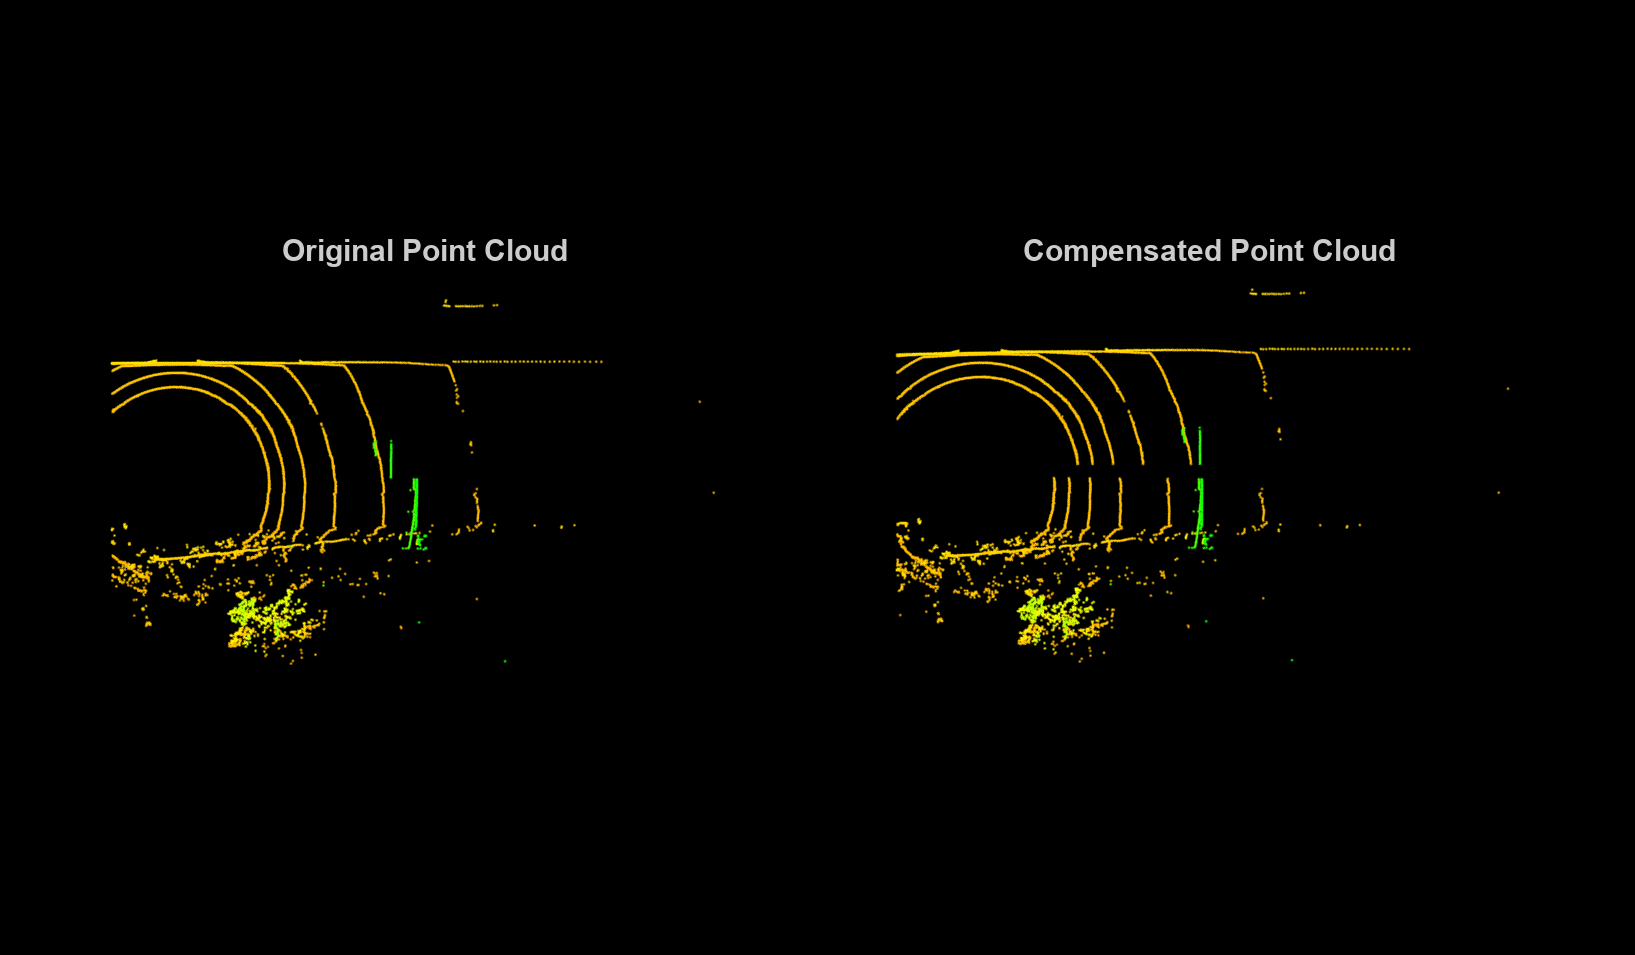
Motion Compensation in 3-D Lidar Point Clouds Using Sensor Fusion
Compensate point cloud distortion due to ego vehicle motion by fusing data from Global Positioning System (GPS) and inertial measurement unit (IMU) sensors. The goal of this example is to compensate the distortion in the point cloud data and recreate the surroundings accurately.
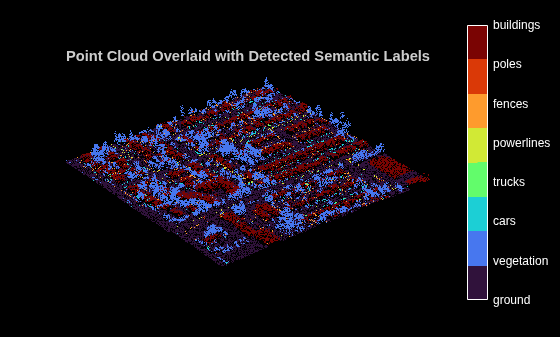
Aerial Lidar Semantic Segmentation Using RandLANet Deep Learning
Train a RandLANet deep learning network to perform semantic segmentation on aerial lidar data.
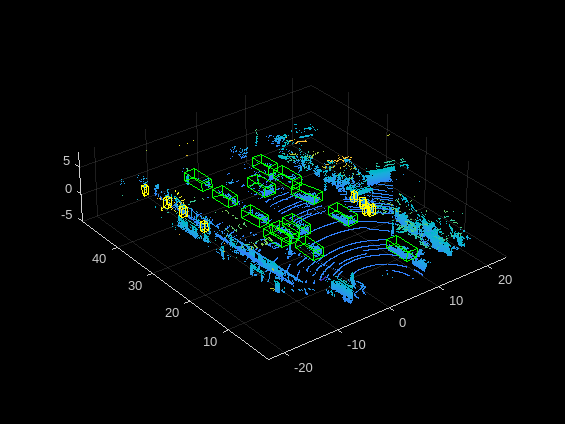
Lidar Object Detection Using Complex-YOLO v4 Network
Detect objects in point clouds using you only look once version 4 (YOLO v4) deep learning network. In this example, you:
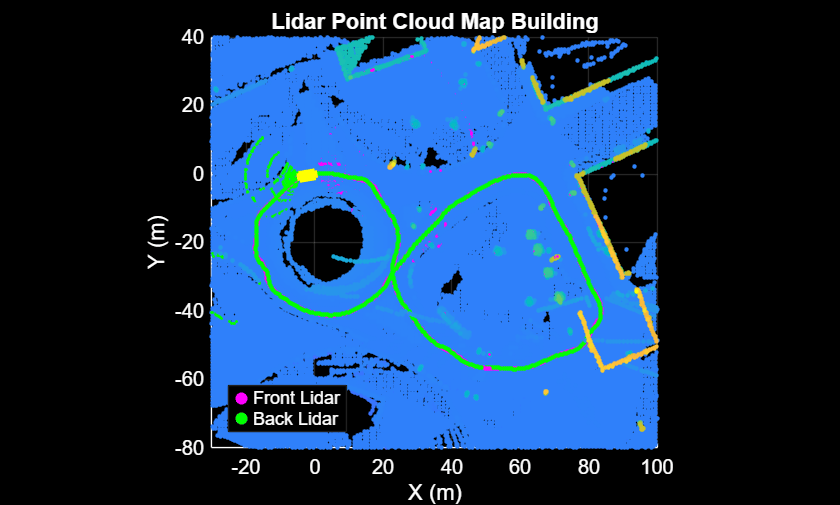
Multi-Lidar Calibration
Calibrate multiple 3-D lidar sensors mounted on a vehicle to estimate a relative transformation between them. Traditional methods, such as marker-based registration, are difficult when the lidar sensors have a negligible overlap between their fields of view (FOVs). The calibration also becomes more difficult as the number of lidar sensors increases. This example demonstrates the use of the trajectories of individual lidar sensors to estimate the transformation between them. This method of calibration is also known as hand-eye calibration.
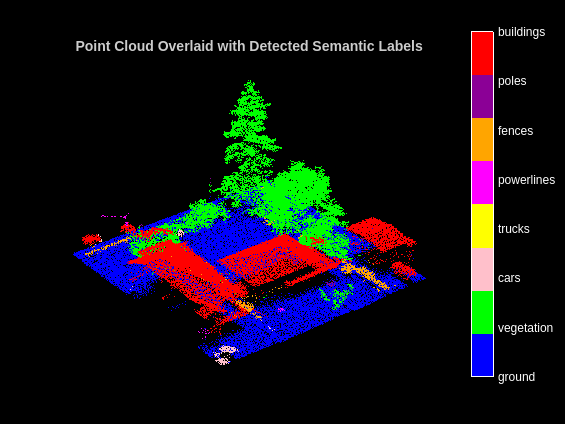
Aerial Lidar Semantic Segmentation Using PointNet++ Deep Learning
Train a PointNet++ deep learning network to perform semantic segmentation on aerial lidar data.
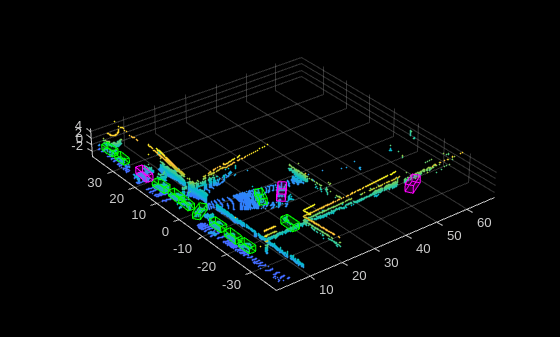
Lidar 3-D Object Detection Using PointPillars Deep Learning
Train a PointPillars network for object detection in point clouds.
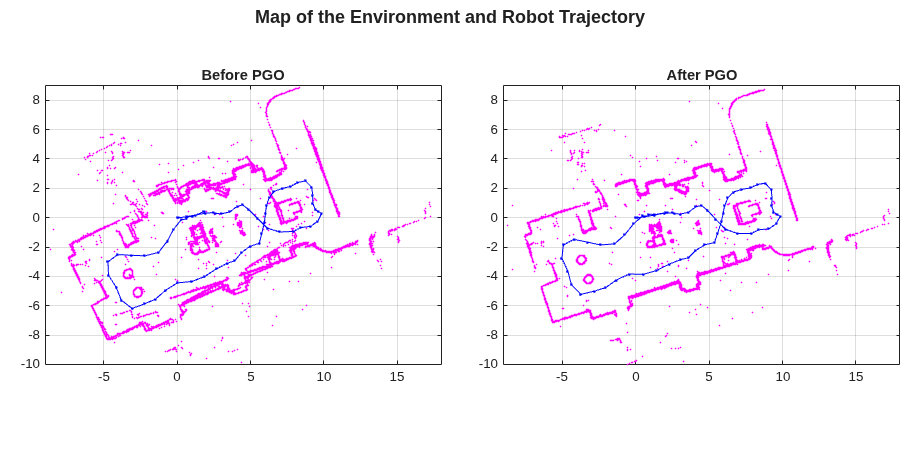
Build Map from 2-D Lidar Scans Using SLAM
Implement the SLAM algorithm on a series of 2-D lidar scans using scan processing and pose graph optimization (PGO). The goal of this example is to estimate the trajectory of the robot and build a map of the environment.
Videos
Lidar Camera Calibration with MATLAB
An introduction to lidar camera calibration functionality, which is an essential
step in combining data from lidar and a camera in a system.
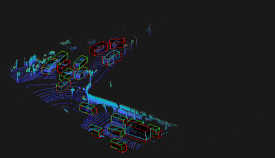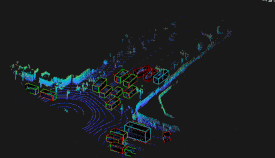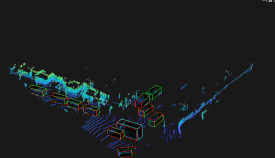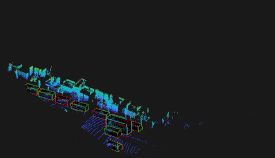
Object Detection on Lidar Point Clouds Using Deep Learning
Learn how to use a PointPillars deep learning network for 3-D object detection
on lidar point clouds.
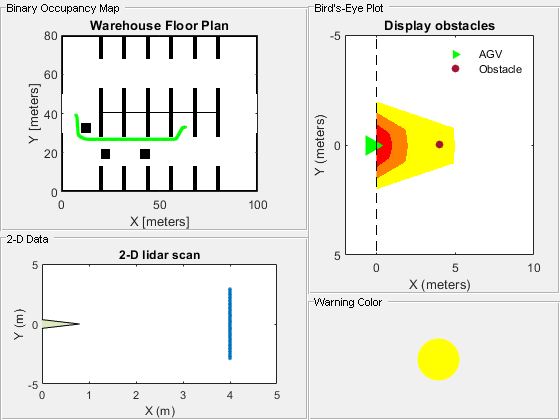
Build a Collision Warning System with 2-D Lidar Using MATLAB
Build a system that can issue collision warnings based on 2-D lidar scans in a
simulated warehouse arena.

