snap
R2026bDescription
Add-On Required: This feature requires the Point Cloud Toolbox Model for SNAP Segmentation Network add-on.
The snap object creates a pretrained Segment Anything in Any
Point Cloud (SNAP) model for segmenting objects in point cloud data. The object enables you to
segment indoor, outdoor, and aerial point cloud scenes by configuring the model for a specific
scene type. The pretrained SNAP model uses only the XYZ coordinates of the input point cloud
and ignores additional point attributes, such as color and intensity.
Use the segmentObjects object function to segment user-specified
objects using foreground point prompts. Use the segmentAllObjects
function to automatically perform instance-level segmentation of all objects in a
scene.
Creation
Description
segmenter = snap(sceneType)
The pretrained SNAP model has been trained on multiple point cloud data sets spanning indoor, outdoor, and aerial scenes. For example, indoor data is associated with the ScanNet data set, outdoor data with KITTI, nuScenes, and PandaSet data sets, and aerial data with STPLS3D and DALES data sets.
Input Arguments
Output Arguments
Properties
Object Functions
segmentObjects | Segment selected objects in point cloud using SNAP model |
segmentAllObjects | Segment all objects automatically in point cloud using SNAP model |
releaseGPUMemory | Release GPU memory allocated for model |
Examples
Create a SNAP segmentation model configured for outdoor point cloud data.
segmenter = snap("Outdoor");Read the input point cloud representing outdoor urban driving scene.
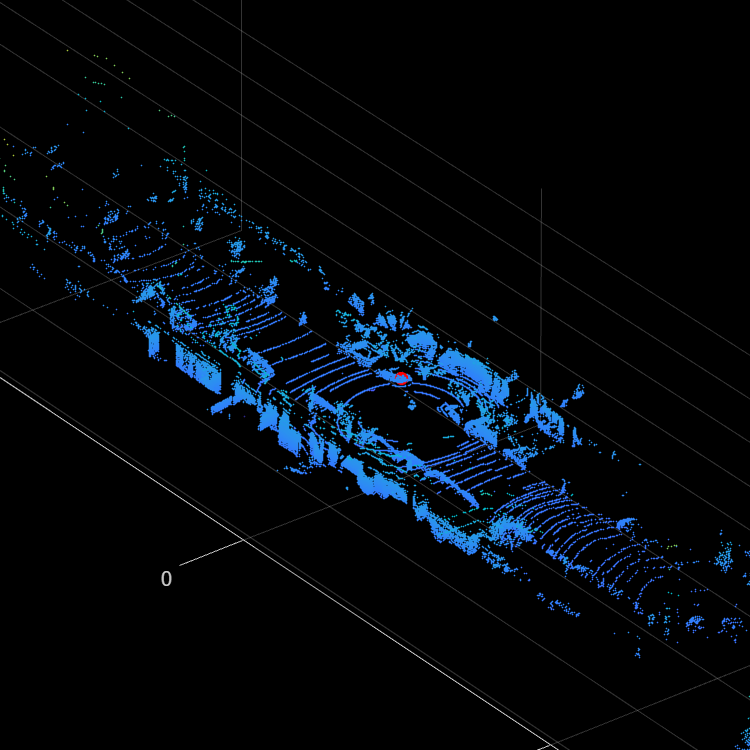
ptCloud = pcread("PandasetLidarData.pcd");Specify a point prompt that lies inside the object of interest. The prompt guides the model to segment the corresponding object.
pointPrompt = [3 5 -0.5];
Display the input point cloud and overlay the point prompt.
figure(Position=[100 100 500 500])
pcshow(ptCloud)
hold on
plot3(pointPrompt(1),pointPrompt(2),pointPrompt(3), ...
    ".r",MarkerSize=20)
hold off
zoom(5)
Segment the object using the segmentObjects object function.
[mask,label,score] = segmentObjects(segmenter,ptCloud,pointPrompt);
Release GPU memory allocated to the SNAP model.
releaseGPUMemory(segmenter)
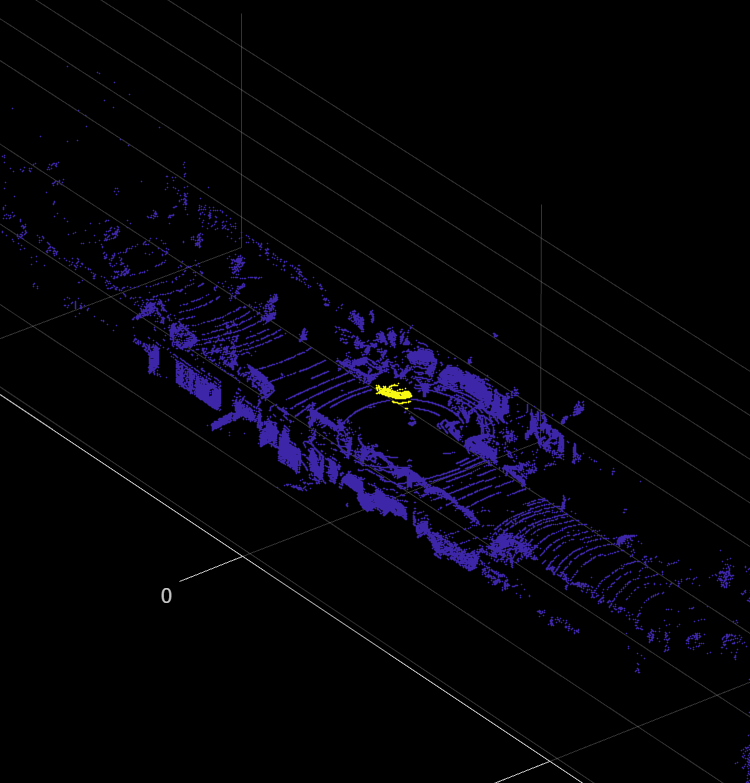
Visualize the segmented object overlaid on the point cloud.
figure(Position=[100 100 500 500])
pcshow(ptCloud.Location,single(mask))
zoom(5)
Display the predicted label.
disp(label)
Car
References
[1] Gupta, Aniket, Hanhui Wang, Charles Saunders, Aruni RoyChowdhury, Hanumant Singh, and Huaizu Jiang. “SNAP: Towards Segmenting Anything in Any Point Cloud.” Preprint, arXiv, 2025.
Version History
Introduced in R2026b
See Also
segmentObjects | segmentAllObjects | releaseGPUMemory | randlanet

