vision.labeler.loading.RosbagSource Class
R2026bNamespace: vision.labeler.loading
Superclasses: vision.labeler.loading.MultiSignalSource
Load signals from ROS or ROS 2 bag file sources into Multi-Sensor Labeler app
Since R2026b
Description
The vision.labeler.loading.RosbagSource class creates an interface for
loading signals from a ROS (.bag) or ROS 2
(.db3, .mcap) bag file into the Multi-Sensor Labeler app. In the Add Signal dialog box of the app, when
Source Type is set to Rosbag, this class
controls the parameters in that dialog box.
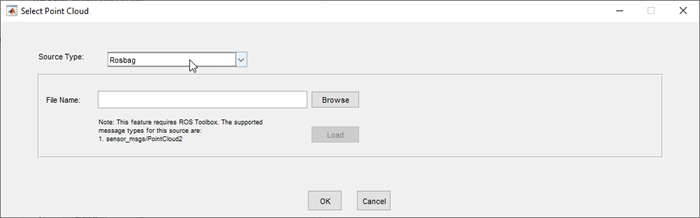
To access this dialog box, in the app, select Import > Add Signal.
This class loads signals from the sensor_msgs/PointCloud2,
sensor_msgs/Image, and
sensor_msgs/CompressedImage ROS message types.
Note
This class requires ROS Toolbox.
The vision.labeler.loading.RosbagSource class is a handle class.
Creation
When you export labels from a Multi-Sensor Labeler app session that contains a
ROS or ROS 2 bag file source, the exported groundTruthMultiSensor object stores an
instance of this class in its DataSource property.
To create a RosbagSource object programmatically, such as when
programmatically creating a groundTruthMultiSensor object, use the
vision.labeler.loading.RosbagSource function (described here).
Description
rosbagSource = vision.labeler.loading.RosbagSourceRosbagSource object for loading signals from a ROS or ROS 2
bag file data source. To specify the data source and the parameters required to load the
source, use the loadSource method.
Properties
Methods
Version History
Introduced in R2026b

