pointCloudObjectDetectorTrainingData
R2026bSyntax
Description
The pointCloudObjectDetectorTrainingData function creates
training data for 3-D object detection from cuboid labels in ground truth data exported from
the Multi-Sensor
Labeler app.
Use the training data to train deep learning networks for lidar object detection, such as
trainPointPillarsObjectDetector. The function extracts point cloud
frames and their corresponding cuboid bounding box labels from a single or an array of groundTruthMultiSensor objects.
trainingData = pointCloudObjectDetectorTrainingData(gTruth)groundTruthMultiSensor object, gTruth. The output table
contains point cloud file paths and corresponding cuboid bounding box labels suitable for
training 3-D point cloud object detection networks such as PointPillars.
___ = pointCloudObjectDetectorTrainingData(
specifies options using one or more name-value arguments. For example,
gTruth,Name=Value)SignalName="lidarSequence" specifies the point cloud signal to
use.
Examples
Input Arguments
Name-Value Arguments
Output Arguments
Labeled data for training the network, returned as a table with two or more columns. The first column of the table contains point cloud file names with paths. Each of the remaining columns corresponds to a cuboid ROI label and contains the locations of bounding boxes in the point cloud sample (specified in the first column), for that label. The bounding boxes are specified as a
M-by-9 numeric matrix with rows of the form
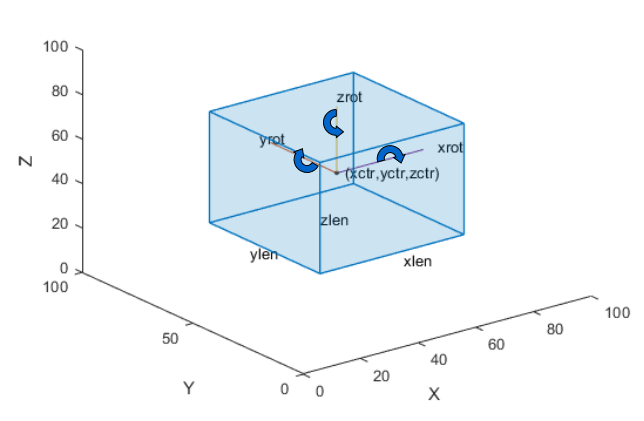
[xctr, yctr, zctr, xlen, ylen, zlen, xrot, yrot, zrot], where:
Mis the number of labels in the frame.xctr,yctr, andzctrspecify the center of the cuboid.xlen,ylen, andzlenspecify the length of the cuboid along the x-axis, y-axis, and z-axis, respectively, before rotation has been applied.xrot,yrot, andzrotspecify the rotation angles for the cuboid along the x-axis, y-axis, and z-axis, respectively. These angles are clockwise-positive when looking in the forward direction of their corresponding axes.
The figure shows how these values determine the position of a cuboid.
Use this table as input for training 3-D object detection networks. For example, use
the training data with trainPointPillarsObjectDetector.
Extracted point cloud data, returned as a fileDatastore object. The point cloud data contains only frames with at
least one cuboid label. The function ignores unlabeled point cloud frames.
To create a datastore for training the network, combine the file and box label
datastores by using combine(pcds, blds). Use the
combined datastore to train deep learning networks for 3-D object detection.
Extracted ROI labels, returned as a boxLabelDatastore (Computer Vision Toolbox) object. The datastore contains M-by-9 matrices of M bounding boxes and
categorical vectors of cuboid ROI label names.
The bounding boxes are specified as a
M-by-9 numeric matrix with rows of the form
[xctr, yctr, zctr, xlen, ylen, zlen, xrot, yrot, zrot], where:
Mis the number of labels in the frame.xctr,yctr, andzctrspecify the center of the cuboid.xlen,ylen, andzlenspecify the length of the cuboid along the x-axis, y-axis, and z-axis, respectively, before rotation has been applied.xrot,yrot, andzrotspecify the rotation angles for the cuboid along the x-axis, y-axis, and z-axis, respectively. These angles are clockwise-positive when looking in the forward direction of their corresponding axes.
The figure shows how these values determine the position of a cuboid.
Extended Capabilities
Version History
Introduced in R2026b

